Norwegian version of this page

EPEC - Engineering Predictability with Embodied Cognition (completed)

How can multimodal systems sense, learn, and predict future events?

EPEC.  Engineering predictability with embodied cognition. It says with letters.. Logo.

Humans are superior to computers and robots when it comes to perceiving with eyes, ears and other senses as well as combining perception with learned knowledge to choose the best actions. This project aims to develop human-inspired models of behaviour and perception and to show that these models can predict future actions accurately.

Our inspiration comes from embodied cognition, a concept from psychology proposing that our bodies, perceptions, abilities, and form, influences how we think. Our goal is to exploit the form of various systems to develop predictive reasoning models as alternatives to traditional reactive systems. These models will be applied in interdisciplinary fields of music technology and robotics. In music, we aim to provide everyday people new ways to move within musical spaces. Our models learn about their interactions with smartphones to proactively assist with their future actions. In robotics, we are developing robots with dynamic forms that can change their thinking in response to new body shapes.
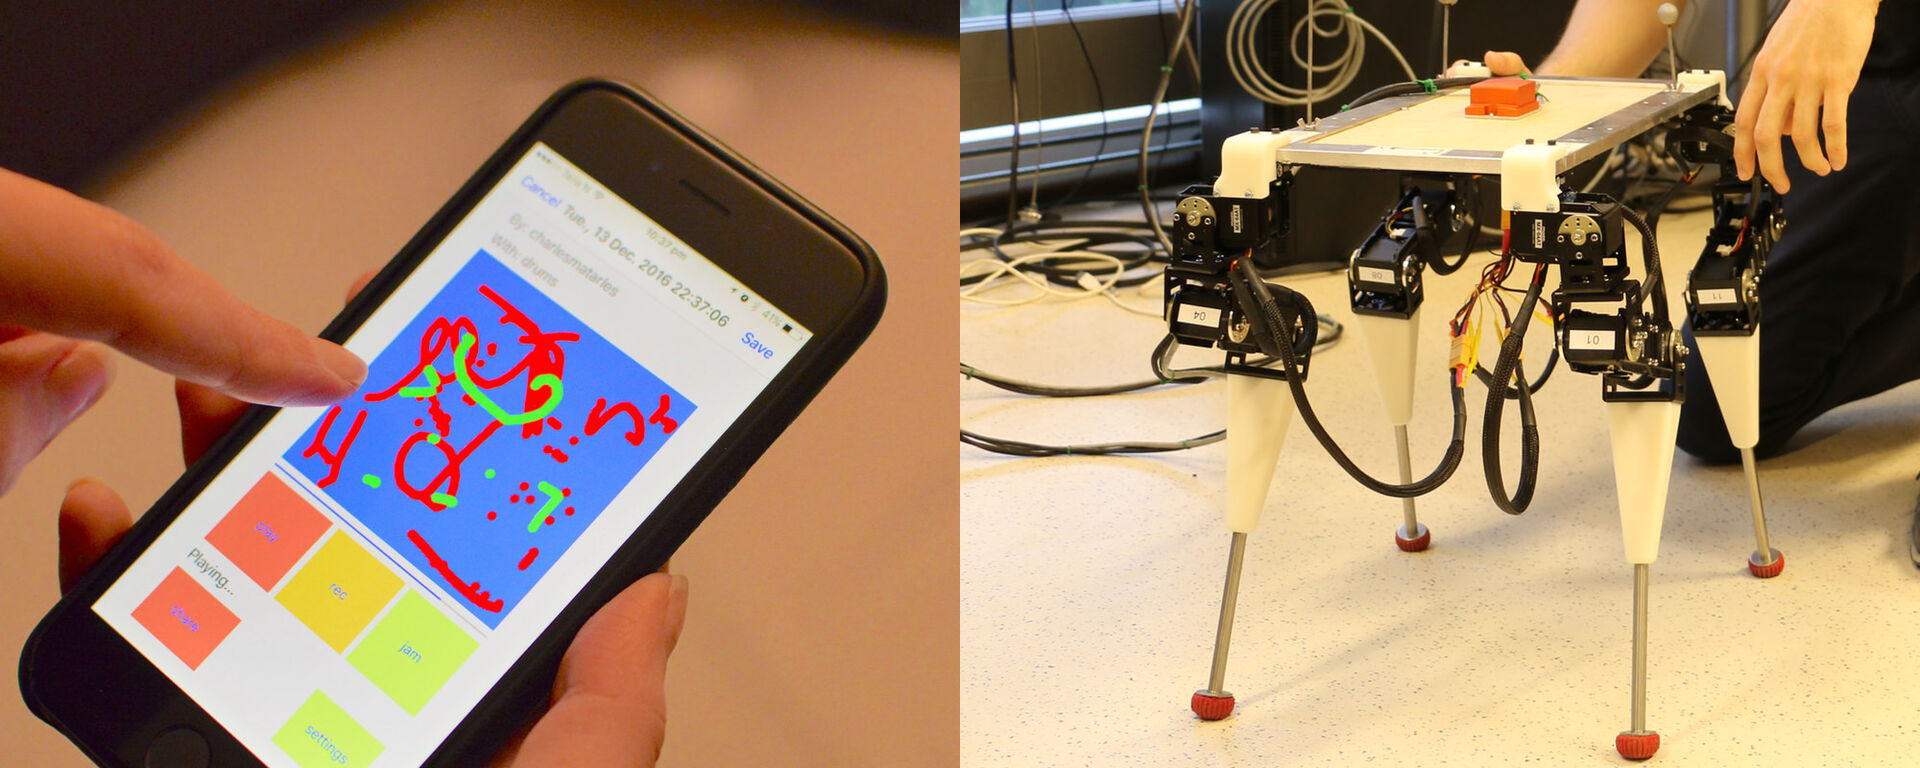
A hand holding a smartphone and feet on some robotics. Photo.
Musical interaction on smartphones and robotic systems, are EPEC's application areas for new predictive models.

EPEC is directed by Professor Jim Tørresen, who also leads the ROBIN research group in the Department of Informatics. The project employs two post doctoral fellows, Kai Olav Ellefsen and Charles Martin, and PhD researcher Tønnes Nygaard. The project also includes Associate Professor Kyrre Glette, PhD researcher Jørgen Nordmoen, and a number of masters students in machine learning, robotics and music technology.

Objectives

Design, implement and evaluate multimodal systems that are able to sense, learn and predict future events.

Sub-projects

  • Internal Models: Predicting real-world effects through internal simulations
  • DyRET: Dynamic Robot for Embodied Testing
  • Interactive music systems: Computer systems for extending and enhancing musical listening, performance and collaboration.

Master Projects

Researchers from the EPEC group supervise master projects in robotics, music technology, and machine learning. Come work with us on predictive models, embodied interactive systems and new robotic interactions!

Funding

Supported by The Research Council of Norway under FRINATEK grant agreement 240862 from 2015 to 2019. The grant funds 1 PhD and 2 post-doc positions (10% of prop. funded).

Publications

  • Jørgen Nordmoen, Tønnes Frostad Nygaard, Eivind Samuelsen & Kyrre Glette (2021). On Restricting Real-Valued Genotypes in Evolutionary Algorithms. In Pedro A. Castillo & Juan Luiz Jiménez Laredo (Ed.), Applications of Evolutionary Computation. Springer. ISSN 9783030726997. p. 3–16. doi: 10.1007/978-3-030-72699-7_1. Full text in Research Archive
  • Tønnes Nygaard, Charles Patrick Martin, Jim Tørresen, Kyrre Glette & David Howard (2021). Real-world embodied AI through a morphologically adaptive quadruped robot. Nature Machine Intelligence. doi: 10.1038/s42256-021-00320-3. Full text in Research Archive
  • Tønnes Nygaard, Charles Patrick Martin, David Howard, Jim Tørresen & Kyrre Glette (2021). Environmental Adaptation of Robot Morphology and Control Through Real-world Evolution. Evolutionary Computation. ISSN 1063-6560. doi: 10.1162/evco_a_00291. Full text in Research Archive
  • Tønnes Nygaard, David Howard & Kyrre Glette (2020). Real world morphological evolution is feasible. In Carlos A. Coello Coello (Eds.), GECCO '20: Proceedings of the 2020 Genetic and Evolutionary Computation Conference Companion. Association for Computing Machinery (ACM). ISSN 9781450371278. p. 1392–1394. doi: 10.1145/3377929.3398095. Full text in Research Archive
  • Charles Patrick Martin, Kyrre Glette, Tønnes Nygaard & Jim Tørresen (2020). Understanding Musical Predictions With an Embodied Interface for Musical Machine Learning. Frontiers in Artificial Intelligence. 3(6). doi: 10.3389/frai.2020.00006. Full text in Research Archive
  • Andrei Faitas, Synne Engdahl Baumann, Torgrim Rudland Næss, Jim Tørresen & Charles Patrick Martin (2019). Generating Convincing Harmony Parts with Simple Long Short-Term Memory Networks. In Marcelo Queiroz & Anna Xambo Sedo (Ed.), Proceedings of the International Conference on New Interfaces for Musical Expression. Universidade Federal do Rio Grande do Sul. Full text in Research Archive
  • Torgrim Rudland Næss & Charles Patrick Martin (2019). A Physical Intelligent Instrument using Recurrent Neural Networks. In Marcelo Queiroz & Anna Xambo Sedo (Ed.), Proceedings of the International Conference on New Interfaces for Musical Expression. Universidade Federal do Rio Grande do Sul. p. 79–82. Full text in Research Archive
  • Charles Patrick Martin & Jim Tørresen (2019). An Interactive Musical Prediction System with Mixture Density Recurrent Neural Networks. In Marcelo Queiroz & Anna Xambo Sedo (Ed.), Proceedings of the International Conference on New Interfaces for Musical Expression. Universidade Federal do Rio Grande do Sul. p. 260–265. Full text in Research Archive
  • Tønnes Frostad Nygaard, Jørgen Halvorsen Nordmoen, Kai Olav Ellefsen, Charles Patrick Martin, Jim Tørresen & Kyrre Glette (2019). Experiences from Real-World Evolution with DyRET: Dynamic Robot for Embodied Testing, Nordic Artificial Intelligence Research and Development: Third Symposium of the Norwegian AI Society, NAIS 2019. Springer. ISSN 9783030356644. p. 58–68. doi: 10.1007/978-3-030-35664-4_6. Full text in Research Archive
  • Kai Olav Ellefsen & Jim Tørresen (2019). Self-adapting Goals Allow Transfer of Predictive Models to New Tasks, Nordic Artificial Intelligence Research and Development: Third Symposium of the Norwegian AI Society, NAIS 2019. Springer. ISSN 9783030356644. p. 28–39. doi: 10.1007/978-3-030-35664-4_3. Full text in Research Archive
  • Kai Olav Ellefsen, Joost Huizinga & Jim Tørresen (2019). Guiding Neuroevolution with Structural Objectives. Evolutionary Computation. ISSN 1063-6560. 28(1), p. 115–140. doi: 10.1162/evco_a_00250. Full text in Research Archive
  • Justinas Miseikis, Inka Brijacak, Saeed Yahyanejad, Kyrre Glette, Ole Jacob Elle & Jim Tørresen (2019). Two-Stage Transfer Learning for Heterogeneous Robot Detection and 3D Joint Position Estimation in a 2D Camera Image Using CNN. IEEE International Conference on Robotics and Automation (ICRA). ISSN 1050-4729. 2019-May, p. 8883–8889. doi: 10.1109/ICRA.2019.8794077. Full text in Research Archive
  • Tønnes Frostad Nygaard, Charles Patrick Martin, Jim Tørresen & Kyrre Glette (2019). Self-Modifying Morphology Experiments with DyRET: Dynamic Robot for Embodied Testing. IEEE International Conference on Robotics and Automation (ICRA). ISSN 1050-4729. 2019-May, p. 9446–9452. doi: 10.1109/ICRA.2019.8793663. Full text in Research Archive
  • Aline Weber, Lucas N. Alegre, Jim Tørresen & Bruno Castro da Silva (2019). Parameterized Melody Generation with Autoencoders and Temporally-Consistent Noise. In Federico Visi (Eds.), Music Proceedings of the International Conference on New Interfaces for Musical Expression. Universidade Federal do Rio Grande do Sul. p. 174–179. Full text in Research Archive
  • Benedikte Wallace & Charles Patrick Martin (2019). Comparing models for harmony prediction in an interactive audio looper. Lecture Notes in Computer Science (LNCS). ISSN 0302-9743. 11453 LNCS, p. 173–187. doi: 10.1007/978-3-030-16667-0_12. Full text in Research Archive
  • Charles Patrick Martin & Henry Gardner (2019). Free-Improvised Rehearsal-as-Research for Musical HCI. In Simon Holland, Tom Mudd, Katie Wilkie-McKenna, Andrew McPherson & Marcelo M. Wanderley (Ed.), New Directions in Music and Human-Computer Interaction. Springer. ISSN 9783319920689. p. 269–284. doi: 10.1007/978-3-319-92069-6_17. Full text in Research Archive
  • Tønnes Frostad Nygaard, Charles Patrick Martin, Jim Tørresen & Kyrre Glette (2019). Evolving Robots on Easy Mode: Towards a Variable Complexity Controller for Quadrupeds. Lecture Notes in Computer Science (LNCS). ISSN 0302-9743. 11454 LNCS, p. 616–632. doi: 10.1007/978-3-030-16692-2_41. Full text in Research Archive
  • Jørgen Halvorsen Nordmoen, Tønnes Frostad Nygaard, Kai Olav Ellefsen & Kyrre Glette (2019). Evolved embodied phase coordination enables robust quadruped robot locomotion. In Manuel López-Ibáñez (Eds.), GECCO '19: Proceedings of the Genetic and Evolutionary Computation Conference. Association for Computing Machinery (ACM). ISSN 9781450361118. p. 133–141. doi: 10.1145/3321707.3321762. Full text in Research Archive
  • Bjørn Ivar Teigen, Kai Olav Ellefsen & Jim Tørresen (2019). A Categorization of Reinforcement Learning Exploration Techniques Which Facilitates Combination of Different Methods, Proceedings of the 9th Joint IEEE International Conference on Development and Learning and on Epigenetic Robotics. IEEE (Institute of Electrical and Electronics Engineers). ISSN 9781538681299. p. 189–194. doi: 10.1109/DEVLRN.2019.8850685. Full text in Research Archive
  • Rafael Garcia, Alexandre Xavier Falcao, Alexandru C. Telea, Bruno Castro da Silva, Jim Tørresen & Joao Luiz Dihl Comba (2019). A Methodology for Neural Network Architectural Tuning Using Activation Occurrence Maps. In Chrisina Jayne & Zoltán Somogyvári (Ed.), 2019 International Joint Conference on Neural Networks (IJCNN). IEEE (Institute of Electrical and Electronics Engineers). ISSN 9781728119854. doi: 10.1109/IJCNN.2019.8852223. Full text in Research Archive
  • Charles Patrick Martin & Jim Tørresen (2019). Data Driven Analysis of Tiny Touchscreen Performance with MicroJam. Computer Music Journal. ISSN 0148-9267. 43(4). doi: 10.1162/comj_a_00536. Full text in Research Archive
  • Artur Becker, Henrik Herrebrøden, Victor Evaristo Gonzalez Sanchez, Kristian Nymoen, Carla Maria Dal Sasso Freitas & Jim Tørresen [Show all 7 contributors for this article] (2019). Functional Data Analysis of Rowing Technique Using Motion Capture Data. In Grisha Coleman (Eds.), Proceedings of the 6th International Conference on Movement and Computing. ACM Publications. ISSN 9781450376549. doi: 10.1145/3347122.3347135. Full text in Research Archive
  • Aline Weber, Charles Patrick Martin, Jim Tørresen & Bruno Castro da Silva (2019). Identifying Reusable Early-Life Options, Proceedings of the 9th Joint IEEE International Conference on Development and Learning and on Epigenetic Robotics. IEEE (Institute of Electrical and Electronics Engineers). ISSN 9781538681299. doi: 10.1109/DEVLRN.2019.8850725. Full text in Research Archive
  • Justinas Miseikis, Inka Brijacak, Saeed Yahyanejad, Kyrre Glette, Ole Jacob Elle & Jim Tørresen (2018). Transfer Learning for Unseen Robot Detection and Joint Estimation on a Multi-Objective Convolutional Neural Network, 2018 IEEE International Conference on Intelligence and Safety for Robotics (ISR 2018). IEEE (Institute of Electrical and Electronics Engineers). ISSN 9781538655481. p. 337–342. doi: 10.1109/IISR.2018.8535937. Full text in Research Archive
  • Jørgen Halvorsen Nordmoen, Eivind Samuelsen, Kai Olav Ellefsen & Kyrre Glette (2018). Dynamic mutation in MAP-Elites for robotic repertoire generation, The 2018 Conference on Artificial Life. MIT Press. ISSN 9780262355766. p. 598–605. doi: 10.1162/isal_a_00110. Full text in Research Archive
  • Jørgen Halvorsen Nordmoen, Kai Olav Ellefsen & Kyrre Glette (2018). Combining MAP-Elites and Incremental Evolution to Generate Gaits for a Mammalian Quadruped Robot. Lecture Notes in Computer Science (LNCS). ISSN 0302-9743. 10784 LNCS, p. 719–733. doi: 10.1007/978-3-319-77538-8_48. Full text in Research Archive
  • Rafael Garcia, Alexandru C Telea, Bruno Castro da Silva, Jim Tørresen & Joao Luiz Dihl Comba (2018). A task-and-technique centered survey on visual analytics for deep learning model engineering. Computers & graphics. ISSN 0097-8493. 77, p. 30–49. doi: 10.1016/j.cag.2018.09.018. Full text in Research Archive
  • Charles Patrick Martin & Jim Tørresen (2018). RoboJam: A musical mixture density network for collaborative touchscreen interaction. Lecture Notes in Computer Science (LNCS). ISSN 0302-9743. 10783 LNCS, p. 161–176. doi: 10.1007/978-3-319-77583-8_11. Full text in Research Archive
  • Justinas Miseikis, Patrick Knobelreiter, Inka Brijacak, Saeed Yahyanejad, Kyrre Glette & Ole Jacob Elle [Show all 7 contributors for this article] (2018). Robot localisation and 3D position estimation using a free-moving camera and cascaded convolutional neural networks, 2018 IEEE/ASME International Conference on Advanced Intelligent Mechatronics (AIM 2018). IEEE (Institute of Electrical and Electronics Engineers). ISSN 9781538618554. p. 181–187. doi: 10.1109/AIM.2018.8452236. Full text in Research Archive
  • Justinas Miseikis, Inka Brijacak, Saeed Yahyanejad, Kyrre Glette, Ole Jacob Elle & Jim Tørresen (2018). Multi-Objective Convolutional Neural Networks for Robot Localisation and 3D Position Estimation in 2D Camera Images, 2018 15th International Conference on Ubiquitous Robots (UR 2018). IEEE (Institute of Electrical and Electronics Engineers). ISSN 9781538663356. p. 597–603. doi: 10.1109/URAI.2018.8441813. Full text in Research Archive

View all works in NVA

View all works in NVA

  • Kyrre Glette (2020). Evolutionary algorithms for intelligent robots. Full text in Research Archive
  • Jørgen Halvorsen Nordmoen & Ingrid Fadelli (2019). A new method to enable robust locomotion in a quadruped robot. [Internet]. TechXplore. Full text in Research Archive
  • Justinas Miseikis, Inka Brijacak, Saeed Yahyanejad, Kyrre Glette, Ole Jacob Elle & Jim Tørresen (2019). Two-Stage Transfer Learning for Heterogeneous Robot Detection and 3D Joint Position Estimation in a 2D Camera Image Using CNN. Full text in Research Archive
  • Kai Olav Ellefsen, Joost Huizinga & Jim Tørresen (2019). Guiding Neuroevolution with Structural Objectives. Full text in Research Archive
  • Tønnes Frostad Nygaard, Charles Patrick Martin, Jim Tørresen & Kyrre Glette (2019). Self-Modifying Morphology Experiments with DyRET: Dynamic Robot for Embodied Testing. Full text in Research Archive
  • Tønnes Frostad Nygaard, Jørgen Halvorsen Nordmoen, Charles Patrick Martin, Jim Tørresen & Kyrre Glette (2019). Lessons Learned from Real-World Experiments with DyRET: the Dynamic Robot for Embodied Testing. Full text in Research Archive
  • Kyrre Glette (2019). Kunstig intelligens for tilpasningsdyktige roboter. Full text in Research Archive
  • Jim Tørresen (2019). Intelligent and Adaptive Robots in Real-World Environment. Full text in Research Archive
  • Jim Tørresen (2019). Future and Ethical Perspectives of Robotics and AI. Full text in Research Archive
  • Jim Tørresen (2019). Sensing Human State with Application in Older People Care and Mental Health Treatment. Full text in Research Archive
  • Jun Miura & Jim Tørresen (2019). Intelligent Robot Technologies for Care and Lifestyle Support. Full text in Research Archive
  • Joao Luiz Dihl Comba & Jim Tørresen (2019). Visual Data Analysis of Unstructured and Big Data. Full text in Research Archive
  • Katharina J. Rohlfing & Jim Tørresen (2019). Explainability: an interactive view. Full text in Research Archive
  • Jim Tørresen, Kyrre Glette & Kai Olav Ellefsen (2019). Intelligent, Adaptive Robots in Real-World Scenarios. Full text in Research Archive
  • Jim Tørresen, Kyrre Glette & Kai Olav Ellefsen (2019). Adaptive Robot Body and Control for Real-World Environments. Full text in Research Archive
  • Kai Olav Ellefsen (2019). Hva Kan Roboter Lære av Biologisk Liv? Full text in Research Archive
  • Artur Becker, Henrik Herrebrøden, Victor Evaristo Gonzalez Sanchez, Kristian Nymoen, Carla Maria Dal Sasso Freitas & Jim Tørresen [Show all 7 contributors for this article] (2019). Functional Data Analysis of Rowing Technique Using Motion Capture Data. Full text in Research Archive
  • Jim Tørresen (2019). Intelligent Robots and Systems in Real-World Environment. Full text in Research Archive
  • Jim Tørresen (2019). Design and Control of Robots for Real-World Environment. Full text in Research Archive
  • Tønnes Frostad Nygaard & Kyrre Glette (2019). Her er universitetets mest avanserte, selvlærende robot. [Journal]. Apollon. Full text in Research Archive
  • Kai Olav Ellefsen & Jim Tørresen (2019). Evolutionary Robotics: Automatic design of robot bodies and control. Full text in Research Archive
  • Jim Tørresen (2019). Supporting Older People with Robots for Independent Living. Full text in Research Archive
  • Jim Tørresen (2019). Hva er kunstig intelligens? Full text in Research Archive
  • Jim Tørresen (2019). Artificial Intelligence and Applications in Health and Care. Full text in Research Archive
  • Jim Tørresen (2019). Kunstig intelligens – hvem, hva og hvor. (Eng. Artificial Intelligence – who, what and where). Full text in Research Archive
  • Charles Patrick Martin & Jim Tørresen (2019). An Interactive Musical Prediction System with Mixture Density Recurrent Neural Networks. Full text in Research Archive
  • Torgrim Rudland Næss, Jim Tørresen & Charles Patrick Martin (2019). A Physical Intelligent Instrument using Recurrent Neural Networks. Full text in Research Archive
  • Andrei Faitas, Synne Engdahl Baumann, Jim Torresen & Charles Patrick Martin (2019). Generating Convincing Harmony Parts with Simple Long Short-Term Memory Networks. Full text in Research Archive
  • Charles Patrick Martin & Jim Torresen (2019). An Interactive Music Prediction System with Mixture Density Recurrent Neural Networks. Full text in Research Archive
  • Charles Patrick Martin, Torgrim Rudland Næss, Andrei Faitas & Synne Engdahl Baumann (2019). Session on Musical Prediction and Generation with Deep Learning. Full text in Research Archive
  • Kyrre Glette, Tønnes Frostad Nygaard & Yngve Vogt (2019). Her er universitetets nest selvlærende robot. [Journal]. Teknisk ukeblad. Full text in Research Archive
  • Kai Olav Ellefsen & Jim Tørresen (2019). Self-Adapting Goals Allow Transfer of Predictive Models to New Tasks. Full text in Research Archive
  • Bjørn Ivar Teigen, Kai Olav Ellefsen & Jim Tørresen (2019). A Categorization of Reinforcement Learning Exploration Techniques Which Facilitates Combination of Different Methods. Full text in Research Archive
  • Jørgen Halvorsen Nordmoen, Tønnes Frostad Nygaard, Kai Olav Ellefsen & Kyrre Glette (2019). Evolved embodied phase coordination enables robust quadruped robot locomotion. Full text in Research Archive
  • Tønnes Frostad Nygaard, Jørgen Halvorsen Nordmoen, Kai Olav Ellefsen, Charles Patrick Martin, Jim Tørresen & Kyrre Glette (2019). Experiences from Real-World Evolution with DyRET: Dynamic Robot for Embodied Testing. Full text in Research Archive
  • Jim Tørresen (2019). Making Robots Adaptive and Preferable to Humans. Full text in Research Archive
  • Kyrre Glette (2019). Kunstig intelligens for tilpasningsdyktige roboter. Full text in Research Archive
  • Jim Tørresen (2018). Intelligent Systems for Medical and Healthcare Applications. Full text in Research Archive
  • Tønnes Frostad Nygaard & Luke Dormehl (2018). This robot taught itself how to walk and it’s as clumsy as a newborn deer. [Journal]. Digital Trends. Full text in Research Archive
  • Tønnes Frostad Nygaard & Robbie Gonzales (2018). How a Flock of Drones Developed Collective Intelligence. [Journal]. Wired Science. Full text in Research Archive
  • Tønnes Frostad Nygaard & Loukia Papadopoulos (2018). New Evolving Robot Teaches Itself to Walk Through Trial and Error. [Journal]. Interesting Engineering. Full text in Research Archive
  • Jim Tørresen (2018). Remote Lab and Applications for High Performance and Embedded Architectures. Full text in Research Archive
  • Tønnes Frostad Nygaard & Matt Simon (2018). The shape-shifting robot that evolves by falling down. [Journal]. Wired Science. Full text in Research Archive
  • Hans Jonas Fossum Moen, Kyrre Glette, Tønnes Frostad Nygaard & Mette Johnsrud (2018). Fem felt der vi får en førerløs fremtid. [Internet]. Titan.uio.no. Full text in Research Archive
  • Charles Patrick Martin (2018). Deep Predictive Models in Interactive Music. Full text in Research Archive
  • Kyrre Glette (2018). Automatic design of bodies and behaviors for real-world robots. Full text in Research Archive
  • Charles Patrick Martin, Kyrre Glette, Tønnes Frostad Nygaard & Jim Tørresen (2018). Self-Awareness in a Cyber-Physical Predictive Musical Interface. Full text in Research Archive
  • Tønnes Frostad Nygaard, Charles Patrick Martin, Jim Tørresen & Kyrre Glette (2018). Exploring Mechanically Self-Reconfiguring Robots for Autonomous Design. Full text in Research Archive
  • Charles Patrick Martin (2018). Predictive Music Systems for Interactive Performance. Full text in Research Archive
  • Charles Patrick Martin, Kyrre Glette & Jim Tørresen (2018). Creative Prediction with Neural Networks. Full text in Research Archive
  • Enrique Alejandro Garcia Ceja, Kai Olav Ellefsen, Charles Patrick Martin & Jim Tørresen (2018). Prediction, Interaction, and User Behaviour. Full text in Research Archive
  • Jim Tørresen (2018). Når etikk betyr alt. Full text in Research Archive
  • Jim Tørresen (2018). Kunstig intelligens – hvem, hva og hvor. Full text in Research Archive
  • Adrian Stoica & Jim Tørresen (2018). Robots on the Moon, and their Role in a Future Lunar Economy. Full text in Research Archive
  • Jim Tørresen (2018). Ethical Robots and Autonomous Systems. Full text in Research Archive
  • Tønnes Frostad Nygaard, Vegard Dønnem Søyseth, Jørgen Halvorsen Nordmoen & Kyrre Glette (2018). Stand with the DyRET robot. Full text in Research Archive
  • Tønnes Frostad Nygaard (2018). Real-World Evolution Adapts Robot Morphology and Control to Hardware Limitations. Full text in Research Archive
  • Charles Patrick Martin & Jim Tørresen (2018). Predictive Musical Interaction with MDRNNs. Full text in Research Archive
  • Jim Tørresen (2018). Frelsende eller fatalt? [Journal]. Forskningsetikk. Full text in Research Archive
  • Charles Patrick Martin (2018). Creative Prediction with Neural Networks. Full text in Research Archive
  • Kai Olav Ellefsen (2018). Evolusjonær Robotikk: Automatisk design og kontroll av roboter. Full text in Research Archive
  • Kai Olav Ellefsen & Jim Tørresen (2018). Evolutionary Robotics: Automatic design of robot controllers and bodies. Full text in Research Archive
  • Vegard Dønnem Søyseth, Tønnes Frostad Nygaard, Charles Patrick Martin, Md Zia Uddin & Kai Olav Ellefsen (2018). ROBIN-Stand ved Cutting Edge 2018. Full text in Research Archive
  • Jim Tørresen (2018). Artificial Intelligence Applied for Real-World Systems. Full text in Research Archive
  • Jim Tørresen (2018). Artificial Intelligence – State-of-the-art. Full text in Research Archive
  • Torgrim Rudland Næss, Charles Patrick Martin & Jim Tørresen (2019). A Physical Intelligent Instrument using Recurrent Neural Networks. Universitetet i Oslo. Full text in Research Archive
  • Benedikte Wallace & Charles Patrick Martin (2018). Predictive songwriting with concatenative accompaniment. Universitetet i Oslo. Full text in Research Archive
  • Jim Tørresen, Bjørn Ivar Teigen & Kai Olav Ellefsen (2018). An Active Learning Perspective on Exploration in Reinforcement Learning. Universitetet i Oslo. Full text in Research Archive
  • Henrik Brustad & Charles Patrick Martin (2018). Digital Audio Generation with Neural Networks. Universitetet i Oslo. Full text in Research Archive

View all works in NVA

Tags: machine learning, robotics, interactive music
Published May 24, 2016 3:38 PM - Last modified Sep. 28, 2022 12:53 PM

Contact

Participants

Detailed list of participants